01 · StartThree commands to first contact
Install the host tool, wire a unit and confirm it answers with nxs probe, then upload a patch and stream SI samples. One wheel covers every transport.
Install the host tool →02 · GuidesThe first hour with the hardware
From a fresh Jetson to a dual camera in seven chapters, one path each. Every step gives the command, the output it prints and what the output means.
Open the guides →03 · ReferenceThe released document set
Device reference, host interface, integration manual and patch authoring: the documents locked to the firmware that ships, mirrored here at each release.
Browse the reference →
01 / The hardwareTwo modules
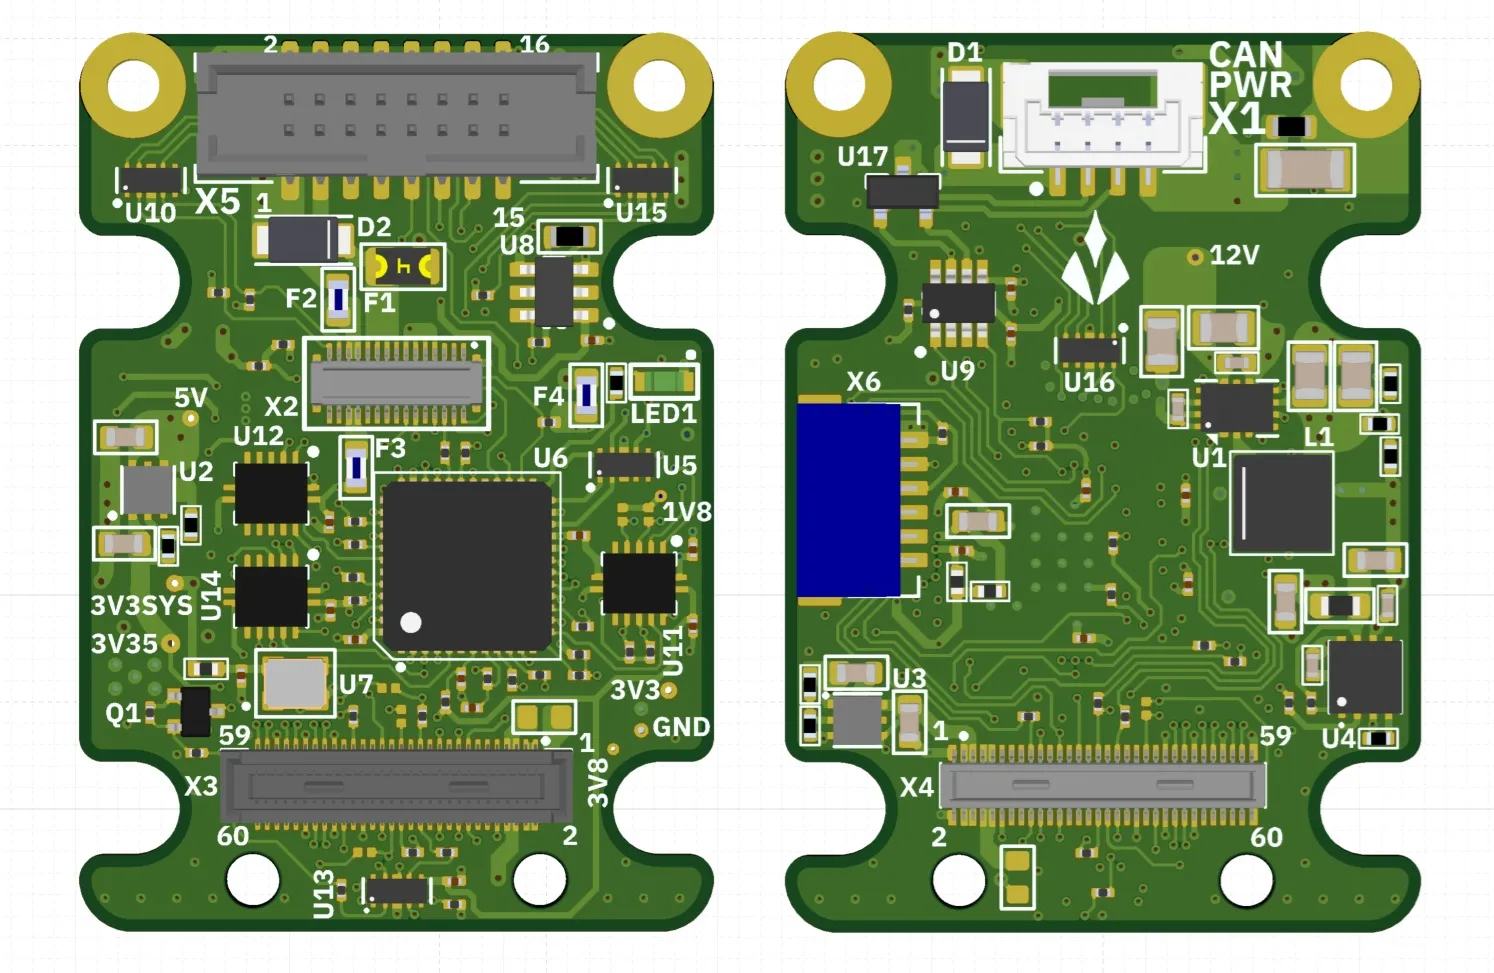
The NXS module carries the sensor and the driver. The NXS Hub brings two GMSL camera links into a host over MIPI CSI-2.
Aliensense NXS
Sensor co-processor · mikroBUS and MIPI · GMSL coax or CAN-FDConnects mikroBUS Click sensors and MIPI cameras to a host over GMSL coax or CAN-FD. Patches are uploaded at run time and measurements arrive in SI units, self-described on the wire.
Product description →Datasheet →
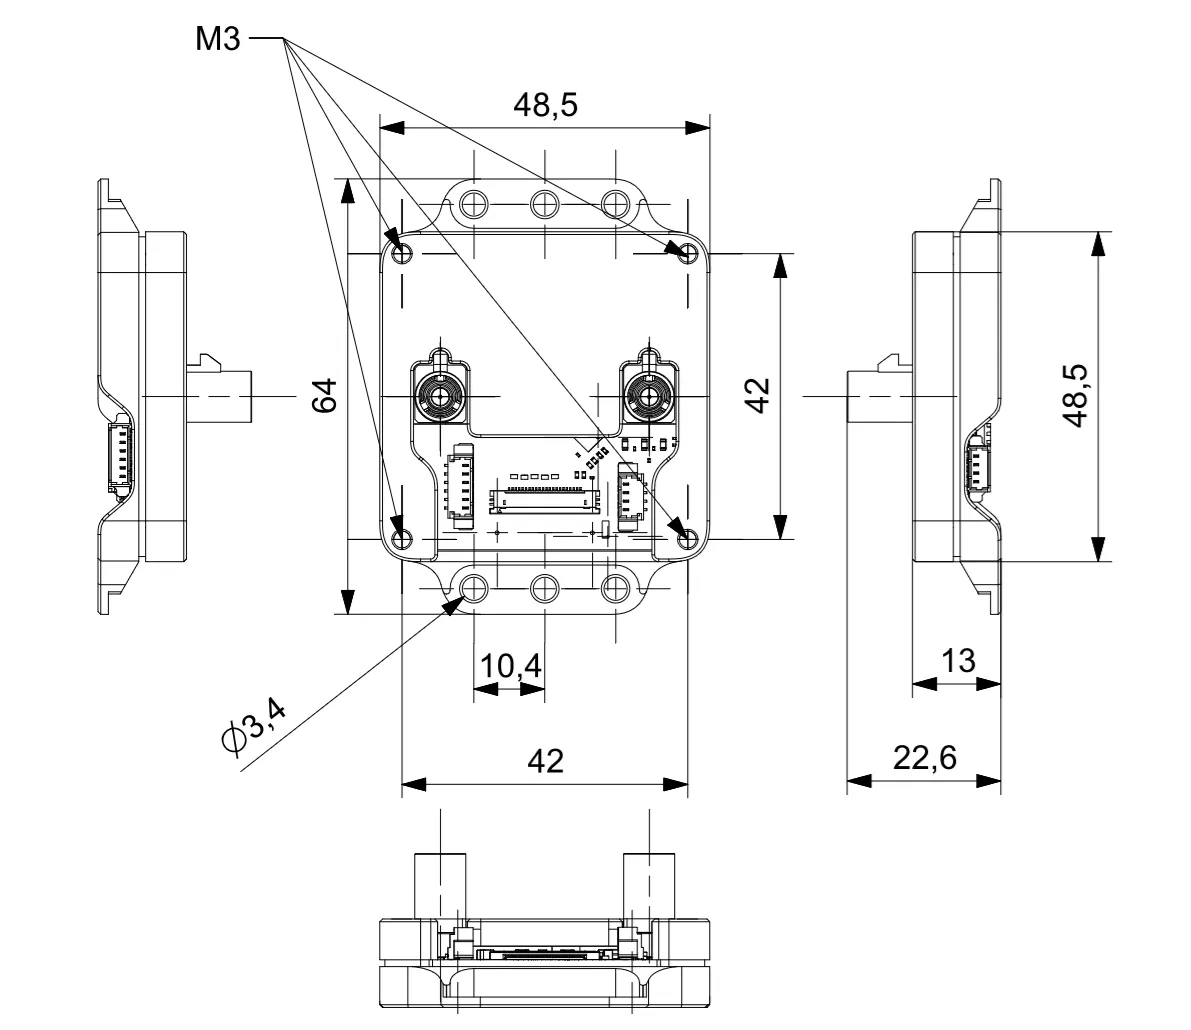
NXS Hub
Camera interface · two GMSL inputs · MIPI CSI-2 outBridges two GMSL camera inputs into a host-friendly MIPI CSI-2 environment: deserialization, power management, control and protection in one module.
Product description →Datasheet →
02 / The documentation setFive sections
About AliensenseAliensense builds sensing infrastructure for robotics. The NXS platform moves the sensor-integration work (hardware interface, driver layer, data transport) onto the module itself, so sensors and cameras placed anywhere on a machine arrive at the compute node as decoded SI-unit data. This documentation set is published from the firmware repository at each release and matches the firmware it ships with.